
Mindmap
position, orientation, and location of a rigid body
Inhalt der Mindmap
position, orientation, and location of a rigid body
the study of the kinematics of robot manipulators, we are constantly dealing with the location of several bodies in space, the bodies of interest include the links of a manipulator, the tools, the workpieces, and so on
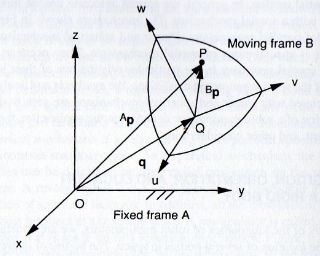
- of a body with respect to a reference coordinate system is known if the position of the body are known. if the body of interest is rigid, six independent parameters would be sufficient to describe its location in three dimensional space
- as shown in
- as shown in
- of a body with respect to a reference coordinate system is known if the position of the body are known. if the body of interest is rigid, six independent parameters would be sufficient to describe its location in three dimensional space
descriiption of position
- of any point eith respect to reference frame can be described by a 3*1 position vector
- of any point eith respect to reference frame can be described by a 3*1 position vector
description of an orientation
- angle representations
- the direction cosine representation of an orientation contains nine parameters, and the screw representation requires four
- the rotation matrix
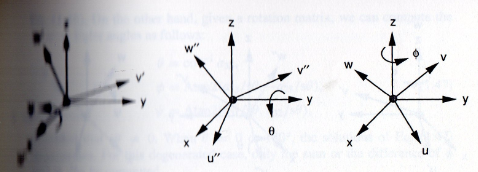
- the resulting rotation matrix is obtained by premultiplying three basic rotation matrices
- the equivalent roll-pitch-yaw angeles as follows
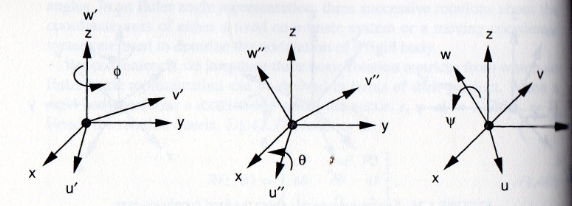
- successive rotations about the moving coordinate axes
- hence the overall rotation matrix
- we can expand
- euler angles as follows
- the resulting rotation matrix is obtained by a postmultiplication of three basic rotation matrices as follows
- the resulting rotation matrix is obtained by a postmultiplication of three basic rotation matrices as follows
- euler angles as follows
- we can expand
- hence the overall rotation matrix
- successive rotations about the moving coordinate axes
- the equivalent roll-pitch-yaw angeles as follows
- the resulting rotation matrix is obtained by premultiplying three basic rotation matrices
- the rotation matrix
- the direction cosine representation of an orientation contains nine parameters, and the screw representation requires four
- axis representation
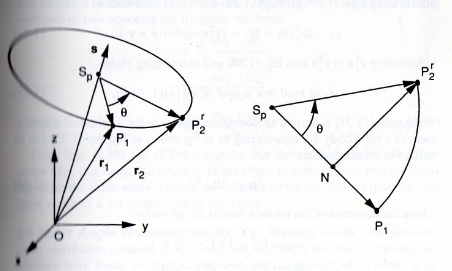
- we seek a description of de orientation of a rigid body in terms of a rotation about a sceww axis
- were the elements of the ratation matrix are given by
- it appears that there are two solutions of the serew axis
- it appears that there are two solutions of the serew axis
- were the elements of the ratation matrix are given by
- we seek a description of de orientation of a rigid body in terms of a rotation about a sceww axis
- direction cosine representation
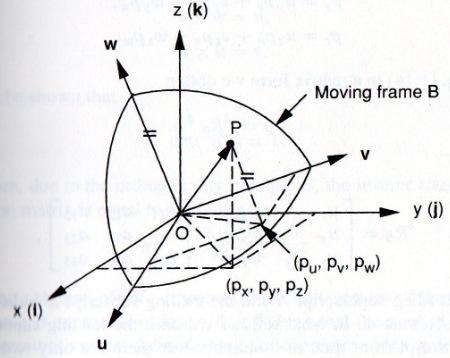
- one convenient way of describing the orientation of a rigid body is by means of the direction cosines of the coordinate axes of the moving frame with respect to the fixed frame, three unit vectors pointing along the coordinate axes of the moving frame B, respectively, as shown in fig.
- the position vector os a point P, and the rotated frame B
- equating x,y,z componets of aP, to the coresponding componets
- matrix from we obtain
- the determinant of the coefficients must vanish
- the determinant of the coefficients must vanish
- matrix from we obtain
- equating x,y,z componets of aP, to the coresponding componets
- the position vector os a point P, and the rotated frame B
- one convenient way of describing the orientation of a rigid body is by means of the direction cosines of the coordinate axes of the moving frame with respect to the fixed frame, three unit vectors pointing along the coordinate axes of the moving frame B, respectively, as shown in fig.
- angle representations
description of a location
- as a pointed out earlier, the location of the rigid body can be described by the position of the origin Q and the orientation of the moving frame with respect in the dixed frame
Bilder und Dateien der Mindmap
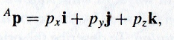
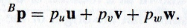
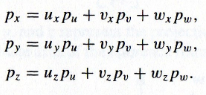
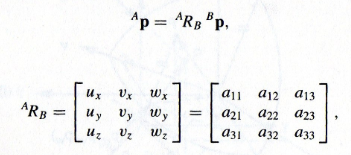
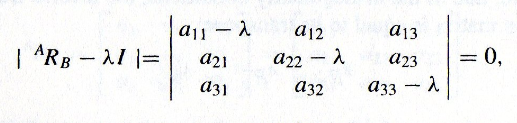
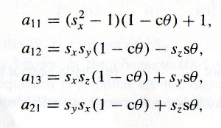
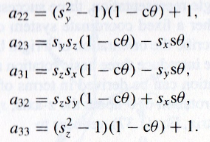
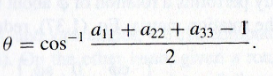
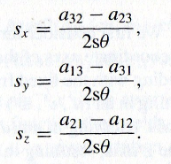
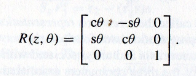
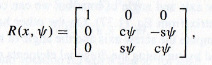
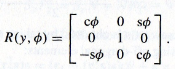
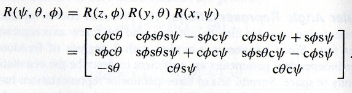
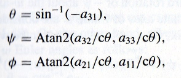
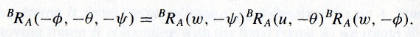
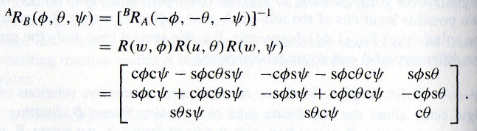
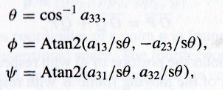
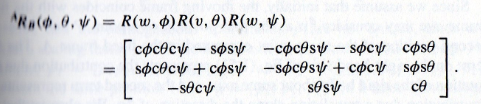
Informationen
- Beschreibung
- the study of the kinematics
- Erstellt von
- juan pablo gacrc
- Aufrufe
- 64
- Tags
- Bewertung