
Mapa mental
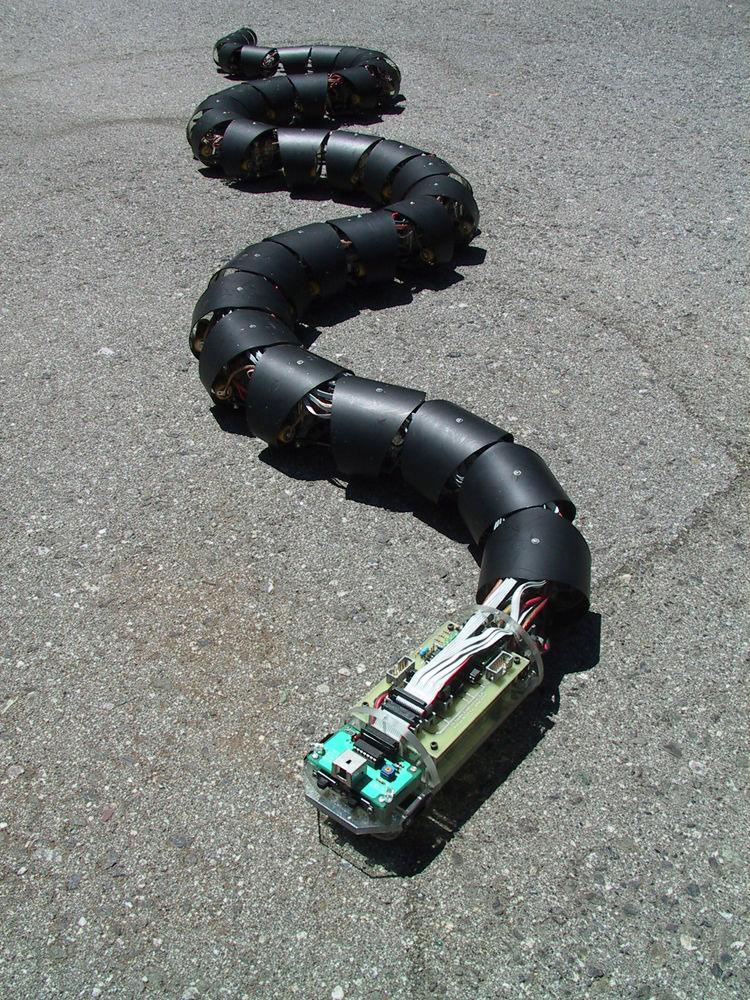
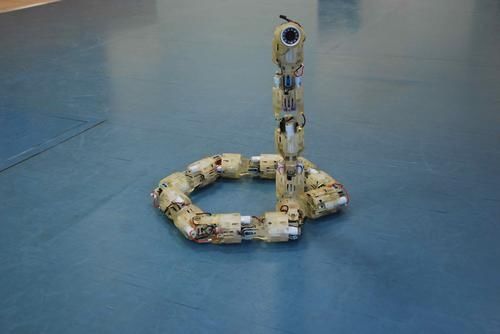
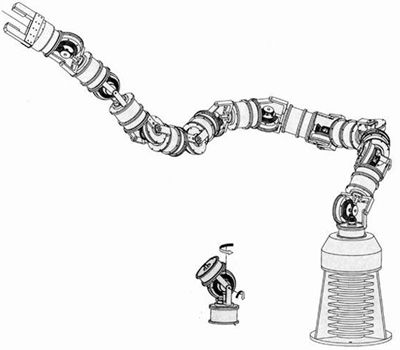
HYPER-REDUNDANT ROBOT
Conteúdo do mapa
HYPER-REDUNDANT ROBOT
CHARACTERISTICS
- Are not anthropomorphic
- Highly linkage structure
- Maneuvering in confined spaces
- Peristaltic waves generated
- Grasp Objects in a Tentacle-Like Fashion
IMPLEMENTATION
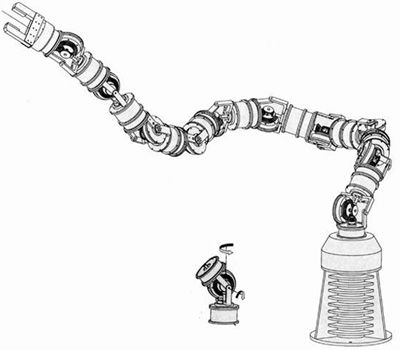
- 30 DOF Robot VGT
- 10 Identical 3 DOF Truss Modules
- 3 Prismatic Joints
- D.C. Servo Motors and Lead Screw Drives
- Linear Potentiometer
- 3 Prismatic Joints
- Casters Attached to the Fixed Elements of the Modules
- can be separated into two robot manipulators 15 DOF
- System is Controlled by an a Multiprocessing Computer
- Heurikon 68030
- mechanical advantage properties
- Gregory S. Chirikjian Joel W. Burdick
- 10 Identical 3 DOF Truss Modules
- 30 DOF Robot VGT
APPLICATIONS
- Medical Endoscopy
- Capturing and Despinning Free Floating Satellites
- Complex Whole Arm Manipulation Experiments
- Emergency Response Vehicles in Collapsed Buildings
- Sensor Placement in Complicated Geological Formations
DISADVANTAGES
- Precise Positioning Tasks
- Not Provide Backbone Torque
MORPHOLOGY
- Continuous Morphology
- Deformable Continuous
- Discrete Morphology
- Rigid Links
- Cascades of Parallel Platform Modules
- Variable Geometry Trusses (VGT)
- Continuous Morphology
UNIVERSIDAD MANUELA BELTRÁN ING. ELECTRÓNICA
- JOHANN ANDRÉS ARGÜELLO CRUZ ROBÓTICA INDUSTRIAL
Imagens e arquivos do mapa
Informações
- Descrição
- Mapa mental sobre robot hyper redundante de 30 grados de libertad
- Criado por
- Johann Andrés Argüello CRUZ
- Visualizações
- 34
- Tags
- Avaliação