
Mindmap
Adaptive Manipulator Control: A Case Study
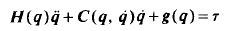
Inhalt der Mindmap
Adaptive Manipulator Control: A Case Study
JEAN-JACQUES E. SLOTINE, WEIPING LI
Manipulator Model
- where q is the n x 1 vector of joint displacements
- T is the n x 1 vector of applied joint torques (or forces)
- g(q) is the n x 1 vector of gravitational torques.
- H(q) is the n x n symmetric positive definite manipulator inertia matrix
- C(q, q)q is the n x 1 vector of centripetal and Coriolis torques
Controller Design
- 1) given the desired joint position qd(t), and with some or all the manipulator parameters unknown
- 2) derive a control law for the actuator torques, and an estimation law for the unknown parameters
- 3) the manipulator joint position q(t) precisely tracks qd( t) after an initial adaptation process
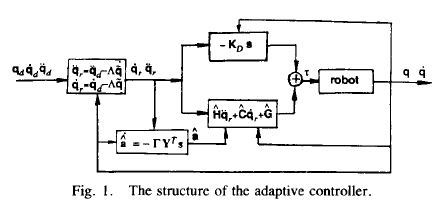
The structure of the adaptive controller given by (3) and (4)
- special form of full dynamics compensation, with three terms corresponding to inertial, centripetal and Coriolis, and gravitational torques
- based on the estimated parameters, attempts to provide the joint dynamic torques necessary to make the desired motions
- actually contains two terms representing PD feedback
- special form of full dynamics compensation, with three terms corresponding to inertial, centripetal and Coriolis, and gravitational torques
Bilder und Dateien der Mindmap
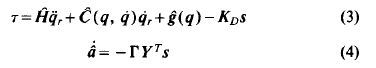
Informationen
- Beschreibung
- Mindmap am Adaptive Manipulator Control: A Case Study, erstellt von Johann Andrés Argüello CRUZ am 29/05/2016.
- Erstellt von
- Johann Andrés Argüello CRUZ
- Aufrufe
- 4
- Bewertung