
Mindmap
Robotics
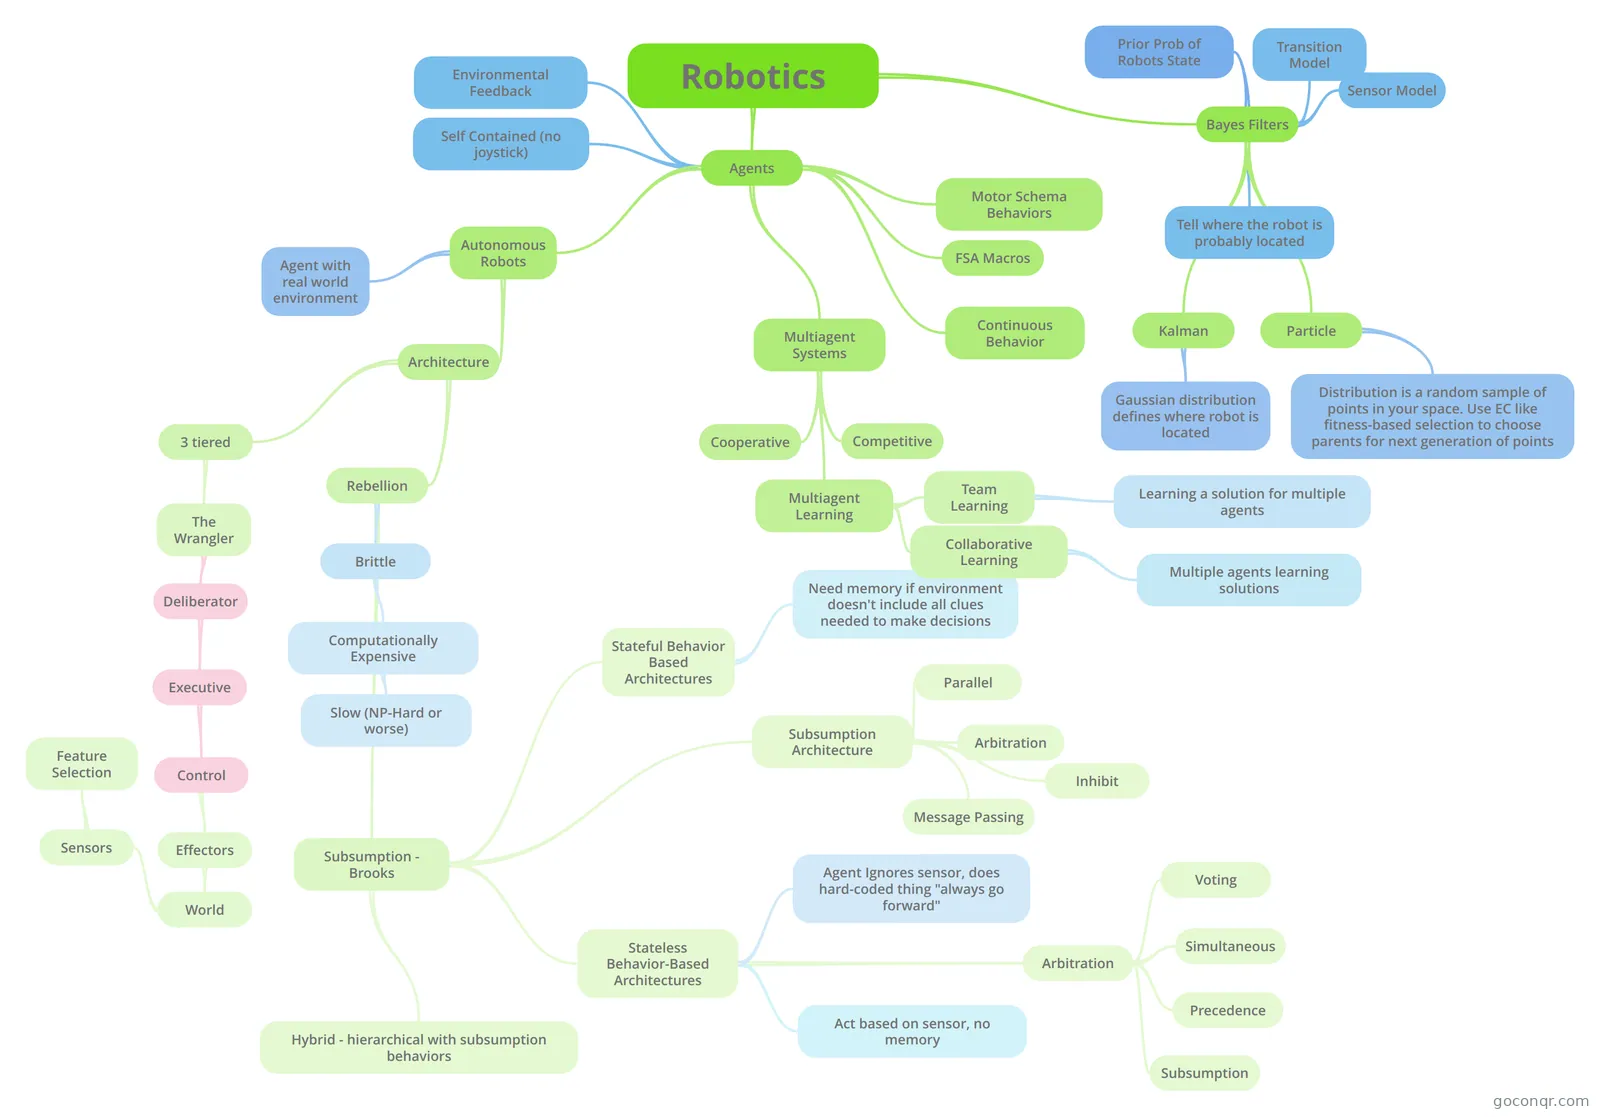
Mind map: Robotics
Inhalt der Mindmap
Robotics
Agents
- Autonomous Robots
- Architecture
- Rebellion
- Brittle
- Computationally Expensive
- Slow (NP-Hard or worse)
- Computationally Expensive
- Subsumption - Brooks
- Stateless Behavior-Based Architectures
- Agent Ignores sensor, does hard-coded thing "always go forward"
- Act based on sensor, no memory
- Arbitration
- Voting
- Simultaneous
- Precedence
- Subsumption
- Stateful Behavior Based Architectures
- Need memory if environment doesn't include all clues needed to make decisions
- Subsumption Architecture
- Parallel
- Arbitration
- Message Passing
- Inhibit
- Hybrid - hierarchical with subsumption behaviors
- Stateless Behavior-Based Architectures
- Brittle
- 3 tiered
- The Wrangler
- Deliberator
- Executive
- Control
- Effectors
- World
- Sensors
- Feature Selection
- Sensors
- World
- Effectors
- Control
- Executive
- Deliberator
- The Wrangler
- Rebellion
- Agent with real world environment
- Architecture
- Continuous Behavior
- FSA Macros
- Motor Schema Behaviors
- Multiagent Systems
- Cooperative
- Competitive
- Multiagent Learning
- Team Learning
- Learning a solution for multiple agents
- Collaborative Learning
- Multiple agents learning solutions
- Team Learning
- Self Contained (no joystick)
- Environmental Feedback
- Autonomous Robots
Bayes Filters
- Kalman
- Gaussian distribution defines where robot is located
- Particle
- Distribution is a random sample of points in your space. Use EC like fitness-based selection to choose parents for next generation of points
- Tell where the robot is probably located
- Prior Prob of Robots State
- Transition Model
- Sensor Model
- Kalman
Informationen
- Beschreibung
- Mindmap am Robotics, erstellt von Jonathan Zinger am 08/05/2014.
- Erstellt von
- Jonathan Zinger
- Aufrufe
- 322
- Tags
- Bewertung