
Mind map
Safe Calculation for Industrial Robotic Control
Map content
Safe Calculation for Industrial Robotic Control
Andreas Platschek, Bernd Thiemann, Heimo Zeilinger, Thilo Sauter. Institute for Computer Technology Vienna University of Technologies
Concept Of The Controller
- Assumptions
- 2)the controller has a safe state. That means if an error is detected, the controller goes into a safe state.
- 1) the controller itself does not directly operate any inputs or outputs, instead all inputs and outputs are made through some kind of industrial communication system
- Description Of Components
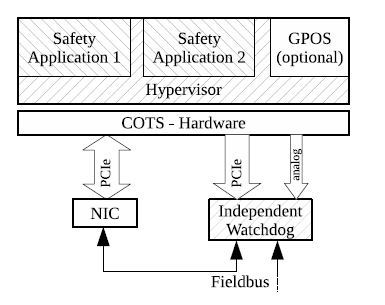
- COTS- Hardware
- This IPC is the computing platform used for safe calculations without itself being part of the safety considerations
- NIC
- The network interface controller (NIC) is a dedicated controller, depending on the fieldbus in use.
- Hypervisor
- The concept is based on a hypervisor that provides the necessary isolation between the two safety applications and between the safety application and the general purpose operating system (GPOS) respectively.
- Independent WatchDog
- The independent watchdog is the only hardware component that has to be considered in the safety process. It is used to monitor specific physical properties of the main computing platform, e.g. (core) temperature and oscillator frequency.
- Safety Applications
- The two safety applications run the same algorithm, with one exception: one of the channels is using an arithmetic code, while the other one is doing the regular calculation in addition to calculating the expected signatures on the side.
- GPOS
- allows the execution of applications that are not safety related
- COTS- Hardware
- Assumptions
Artihmetic Codes
- AN Codes
- based on the idea of creating a space in between valid code words in order to being able to detect invalid code words.
- Floating Point Operations
- use a softfloat library, where the floating point arithmetics that is usually performed in the floating point unit (FPU) of the CPU is emulated in software by using integer operations
- AN Codes
Images and files in the map
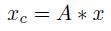
Information
- Description
- Mind Map on Safe Calculation for Industrial Robotic Control, created by Johann Andrés Argüello CRUZ on 30/05/2016.
- Created by
- Johann Andrés Argüello CRUZ
- Views
- 1
- Rating